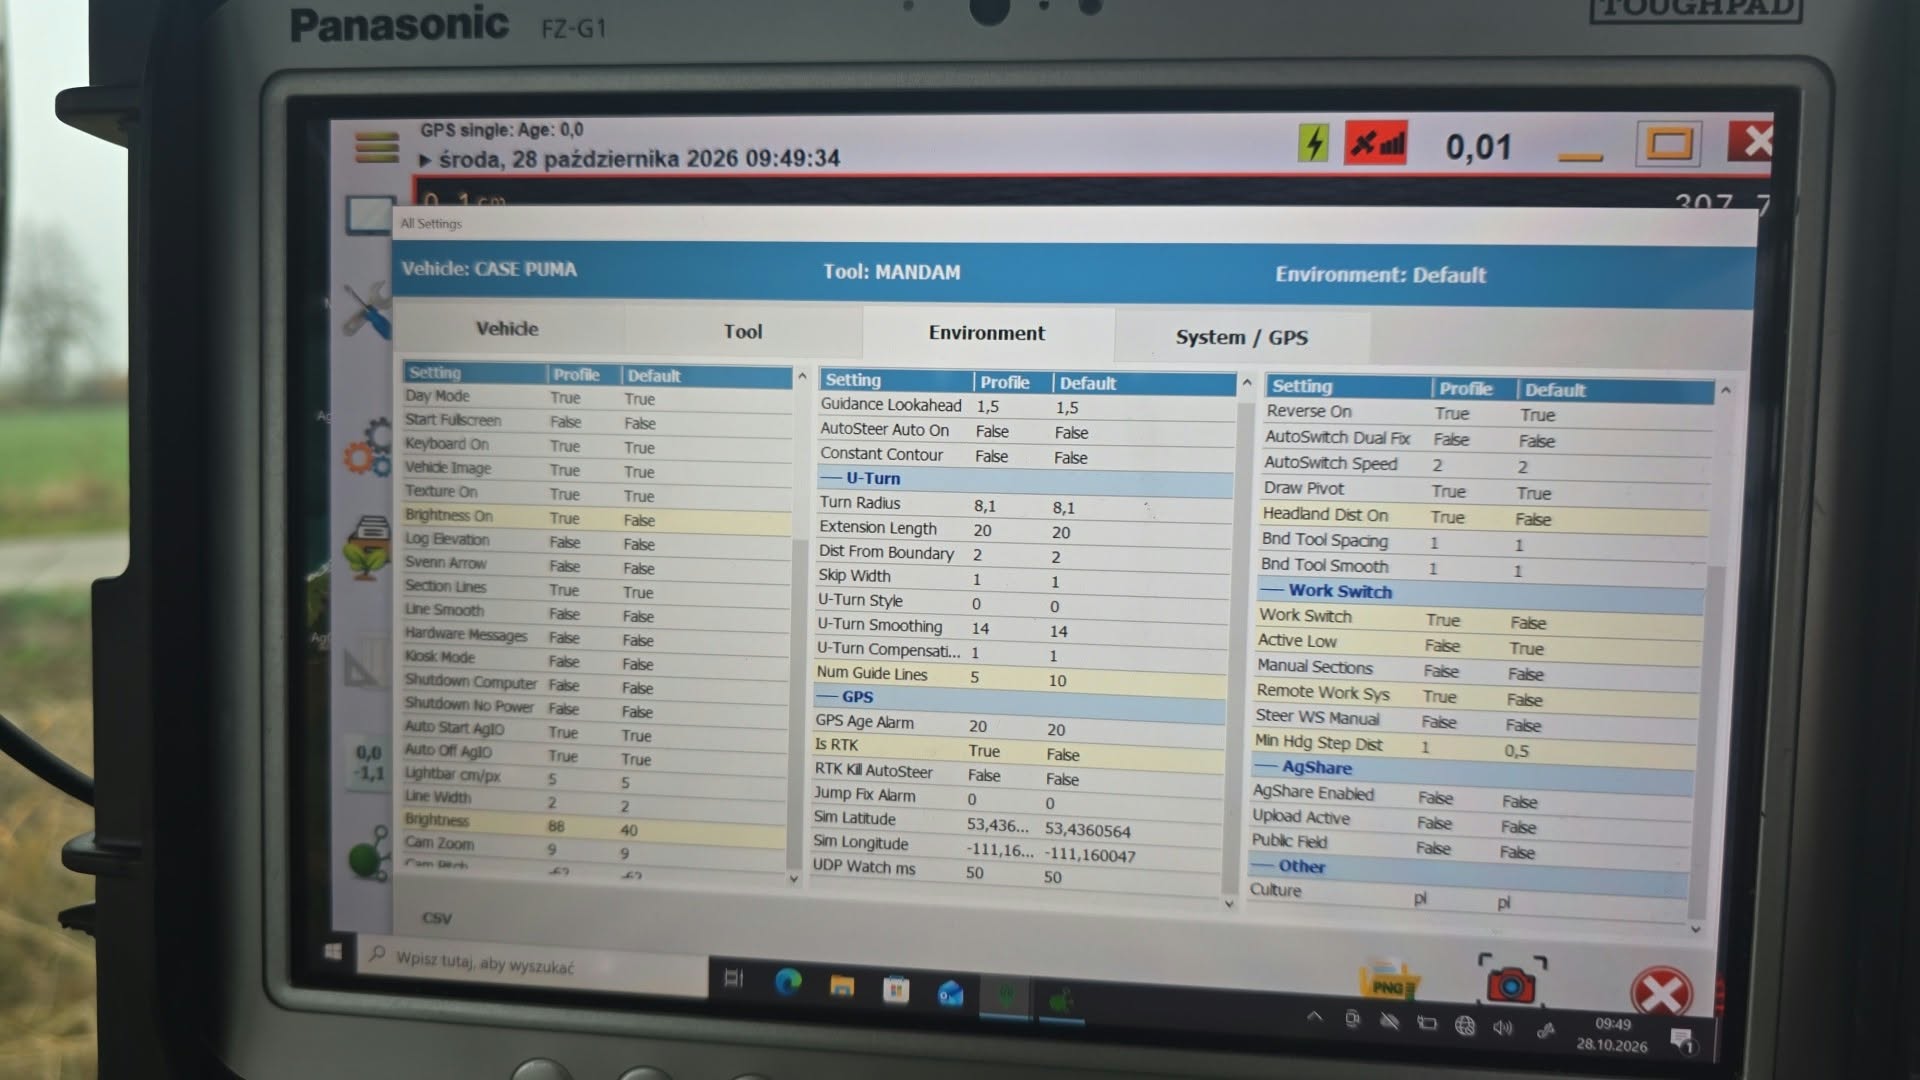
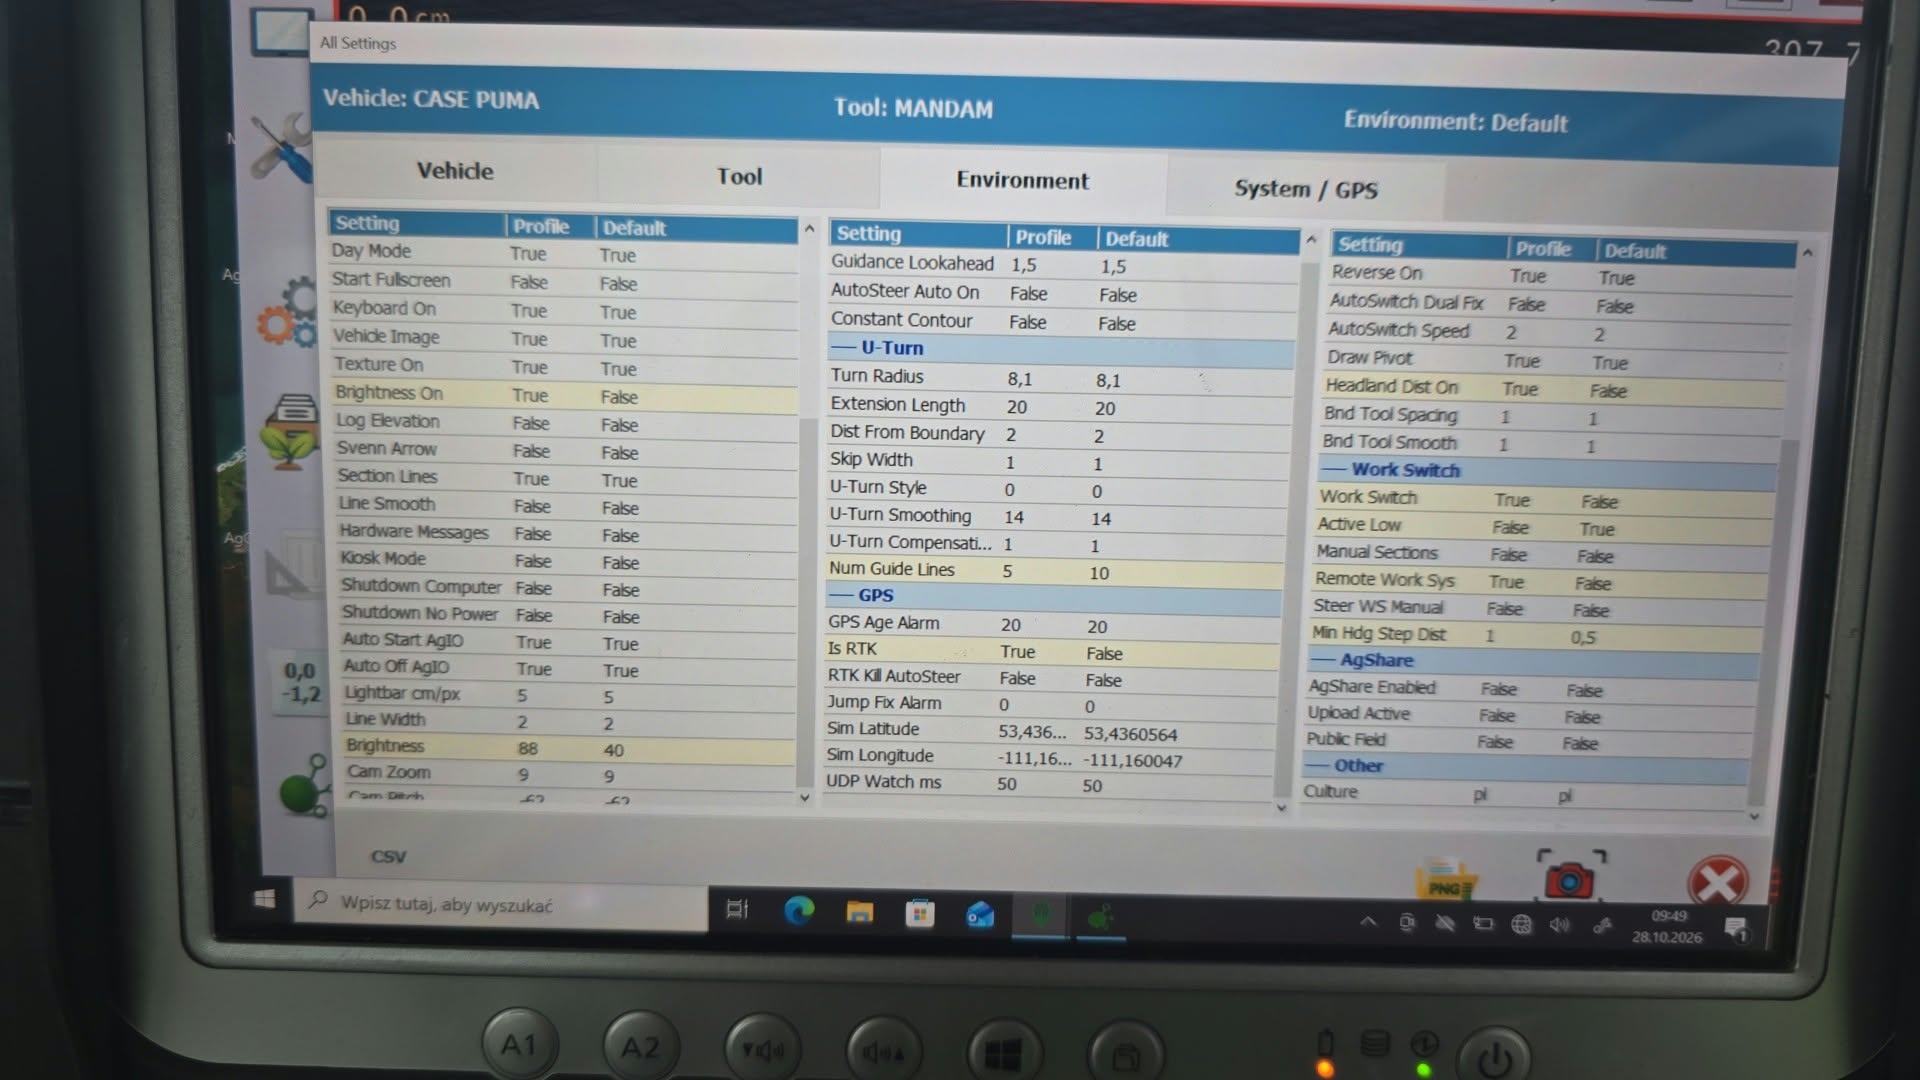
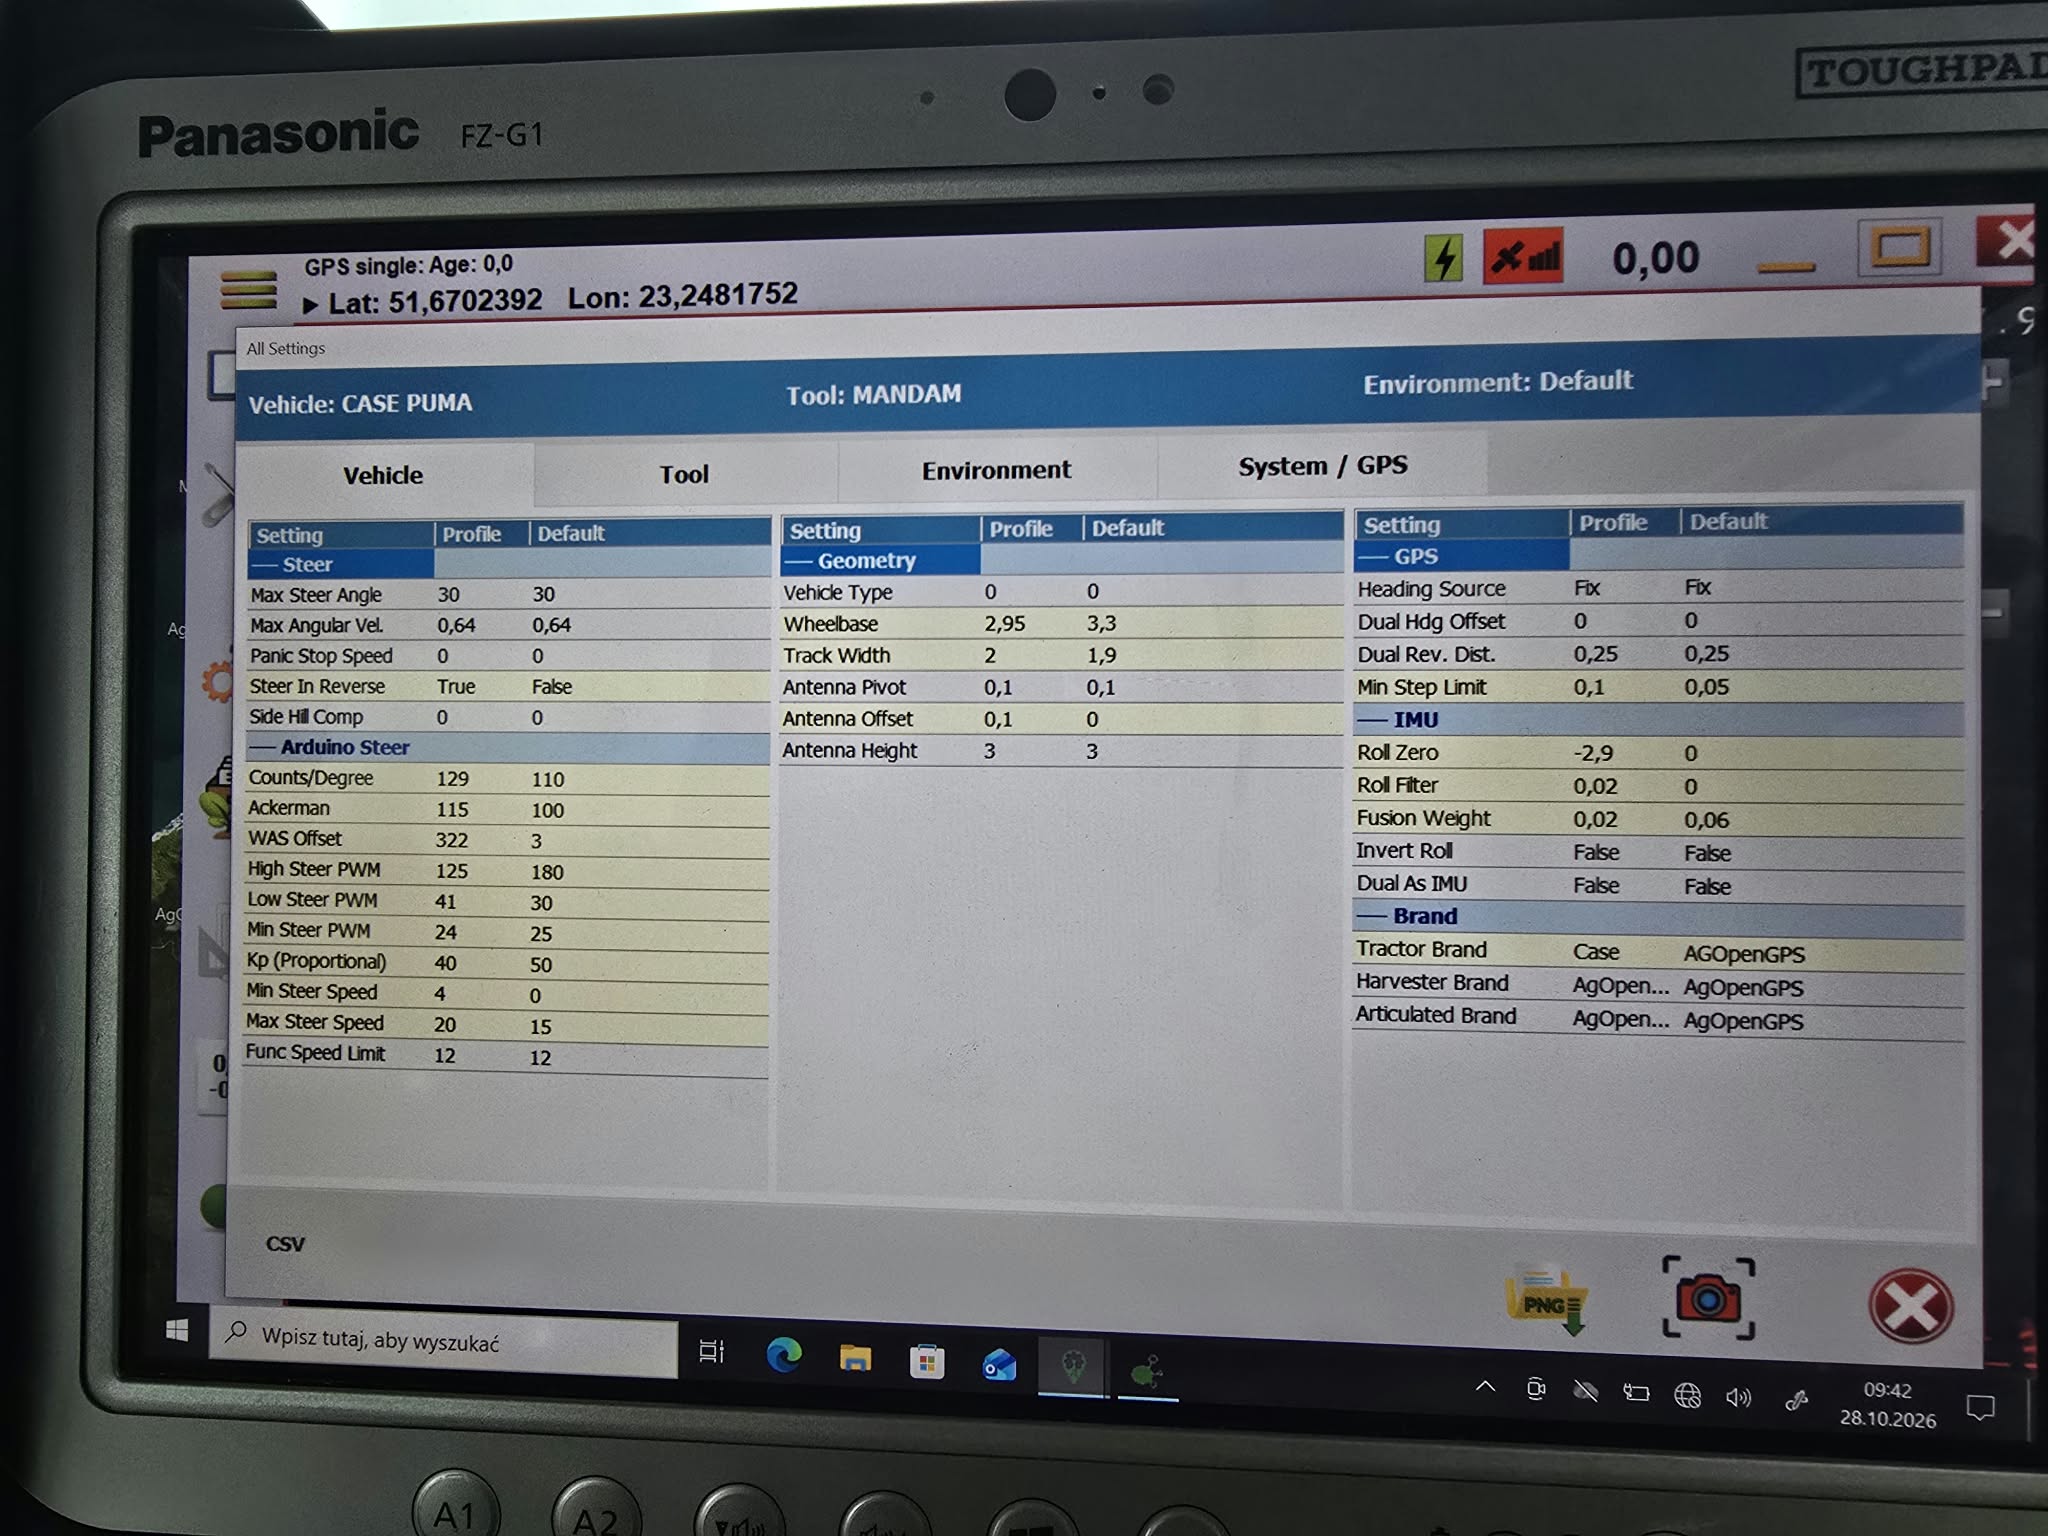
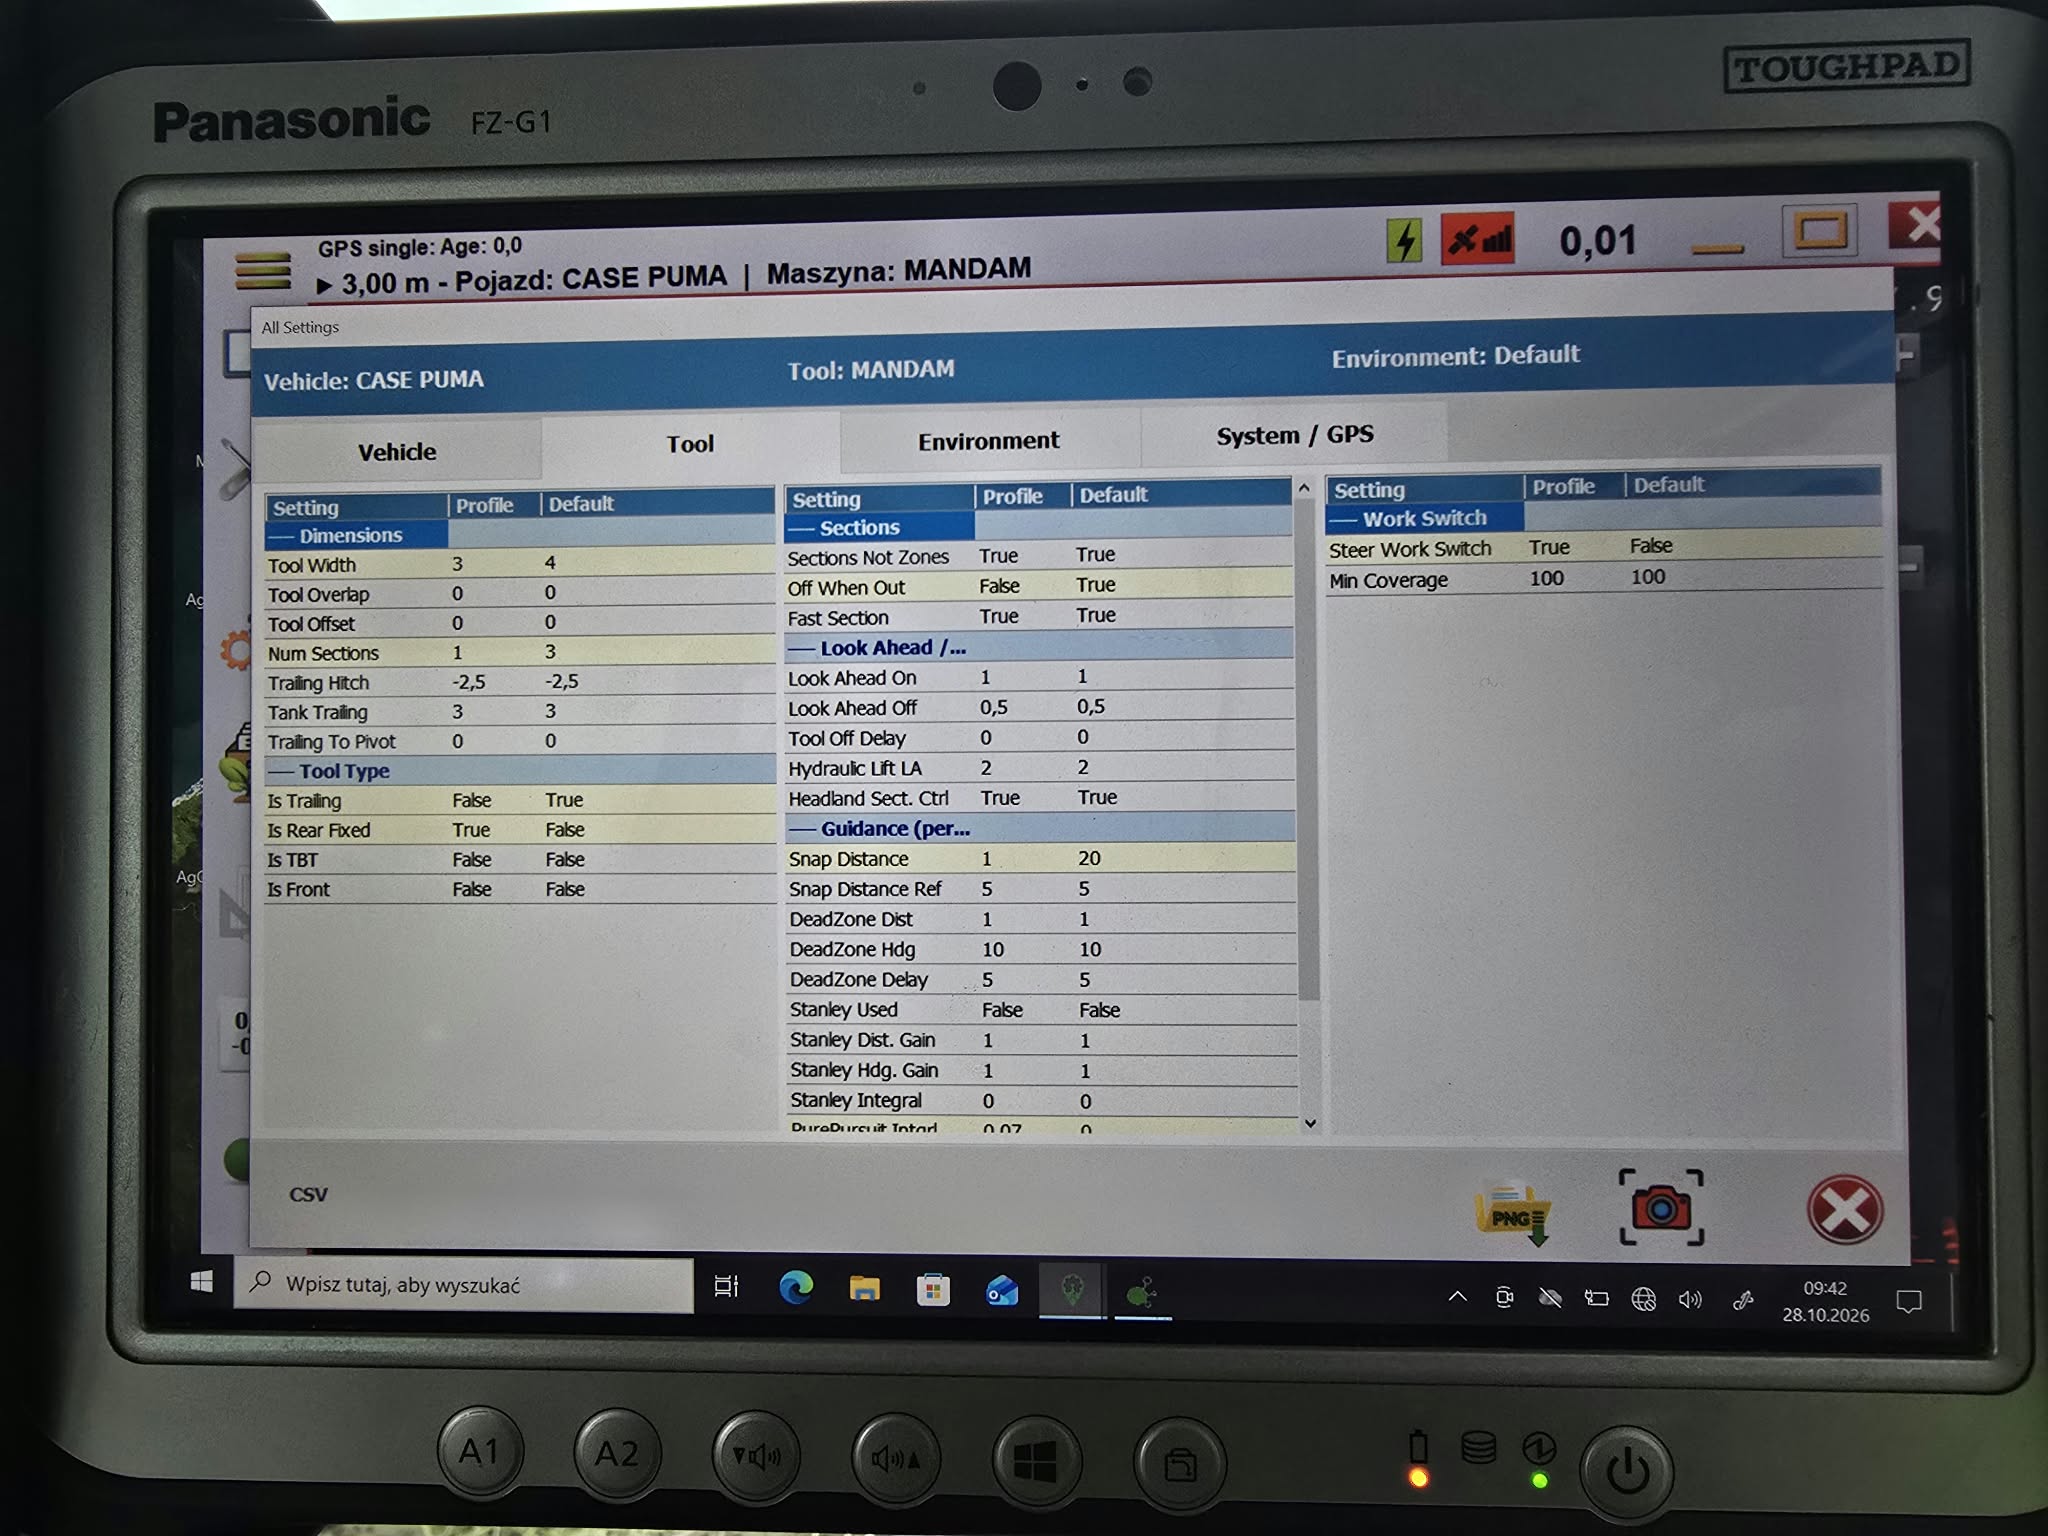
CNH + Keya AutoSteering Issue on Uneven Ground

Hi everyone,

I’m having some trouble getting AutoSteer properly tuned on my CNH tractor.

I’m using a Keya CAN steering motor , Standard AIO v4.5, UM982 and BNO085 IMU.

On flat ground it works quite well. It’s not perfectly straight and doesn’t hold exactly 0° steering angle all the time, but the deviation from the A/B line is usually within ±2 cm , so I’m pretty happy with that.

The problem starts on uneven ground. The tractor begins making unnecessary left-right corrections and sometimes oscillates around ±10 cm from the line.

What’s strange is that when I use the steering test mode and set a fixed steering angle, for example 0° or 4°, the Keya follows it very well without any noticeable oscillations. But as soon as I switch to A/B line guidance, things get much worse on bumpy ground.

I’m using the original CNH WAS, powered by the tractor’s 5 V supply. Looking at the steering angle graph, the signal seems quite stable, and I haven’t noticed any obvious spikes.

I’ve already tried different Gain, Min/Max and Reactivity settings, as well as Roll Filter at 0 and 2, without much improvement.

I’m wondering if the problem could be related to the BNO085, Roll Compensation or IMU/GPS Fusion settings , rather than the steering motor itself.

Has anyone had a similar problem, especially with CNH tractors? What Roll Compensation and IMU/GPS Fusion settings are you using? Could the original 5 V WAS supply cause problems even if the measured angle looks stable?

Any suggestions on what to check next would be appreciated.

Thanks!
As you said it runs well on flat ground, so nothing wrong with your tractor.
Bno has known issues with sideways acceleration. The higher in tractor it sits the worse it gets.
Also the delay in steer system has effects.
Try to set antenna hight to zero meter. Also max the IMU GPS ratio towards IMU.

I’ll try thanks! How about Roll compensation?

You can try, but it will probably add unwanted delay.

I tried two more things.

First, I set the antenna offset to 0 cm, but unfortunately it didn’t make any difference.

Second, I tried powering the original CNH WAS directly with 5 V from the AIO controller instead of using the original tractor supply. This also didn’t improve the steering.

However, when I powered the WAS from the controller’s 5 V supply, I started having another problem with the WAS reading. After some time, the reading would freeze at around -50 degrees and stay there. The only thing that helped was completely switching the whole controller off and back on again.

The Teensy itself still seemed to work correctly because autosteer communication and position data were still being sent to the tablet. Because of that, I suspect that the ADS1115 may be freezing or losing communication while the rest of the Teensy continues to run.

Has anyone had a similar problem with the ADS1115 freezing like this? If so, what was the solution?

I still cannot get consistent 0–2 cm tracking on a straight AB line in the field. The tractor keeps making irregular left/right corrections, but they are not even regular sinusoidal oscillations. The deviations seem quite random and I still cannot find a combination of settings that makes it follow the line properly.

Its a nh WAS, they are absolutely crap. Freezing at full lock points towards the sensor on the way out. Fit a linear sensor before you do anymore.
Sensors on swb models are a wearing part, they are more reliable on the lwb models

It really sounds like a bad connection or possibly a bad sensor. You could have someone wiggle the connections while you watch if the steer angle changes. Or try a different sensor. I’ve had pretty much the same thing happen several times and every time it was bad connectors.

I think the WAS itself is working correctly. The WAS zero position has been calibrated using the Smart WAS function in AgOpenGPS.

I did some more testing using the manual steering function (tractor icon) in AgOpenGPS. When I set any desired steering angle, the system follows it perfectly.

For example, if I set 10°, the tractor turns and maintains exactly 10° without any oscillations. If I set 0°, the tractor drives perfectly straight and holds that angle without any problems.

The Actual steering angle follows the Set angle very well.

However, as soon as I enable autosteer and try to follow an AB line, the tractor starts making irregular left/right corrections and cannot maintain a straight line. The deviations can reach around 10 cm in either direction.

I’ve tried different Gain, Min, Max, Look Ahead and other settings, but nothing seems to solve the problem.

This makes me think that the WAS and steering control loop are probably working correctly, and the issue might be related to how AgOpenGPS calculates the desired steering angle when following an AB line.

Sounds like your imu could be on wrong axis or inverted
What steer settings you using

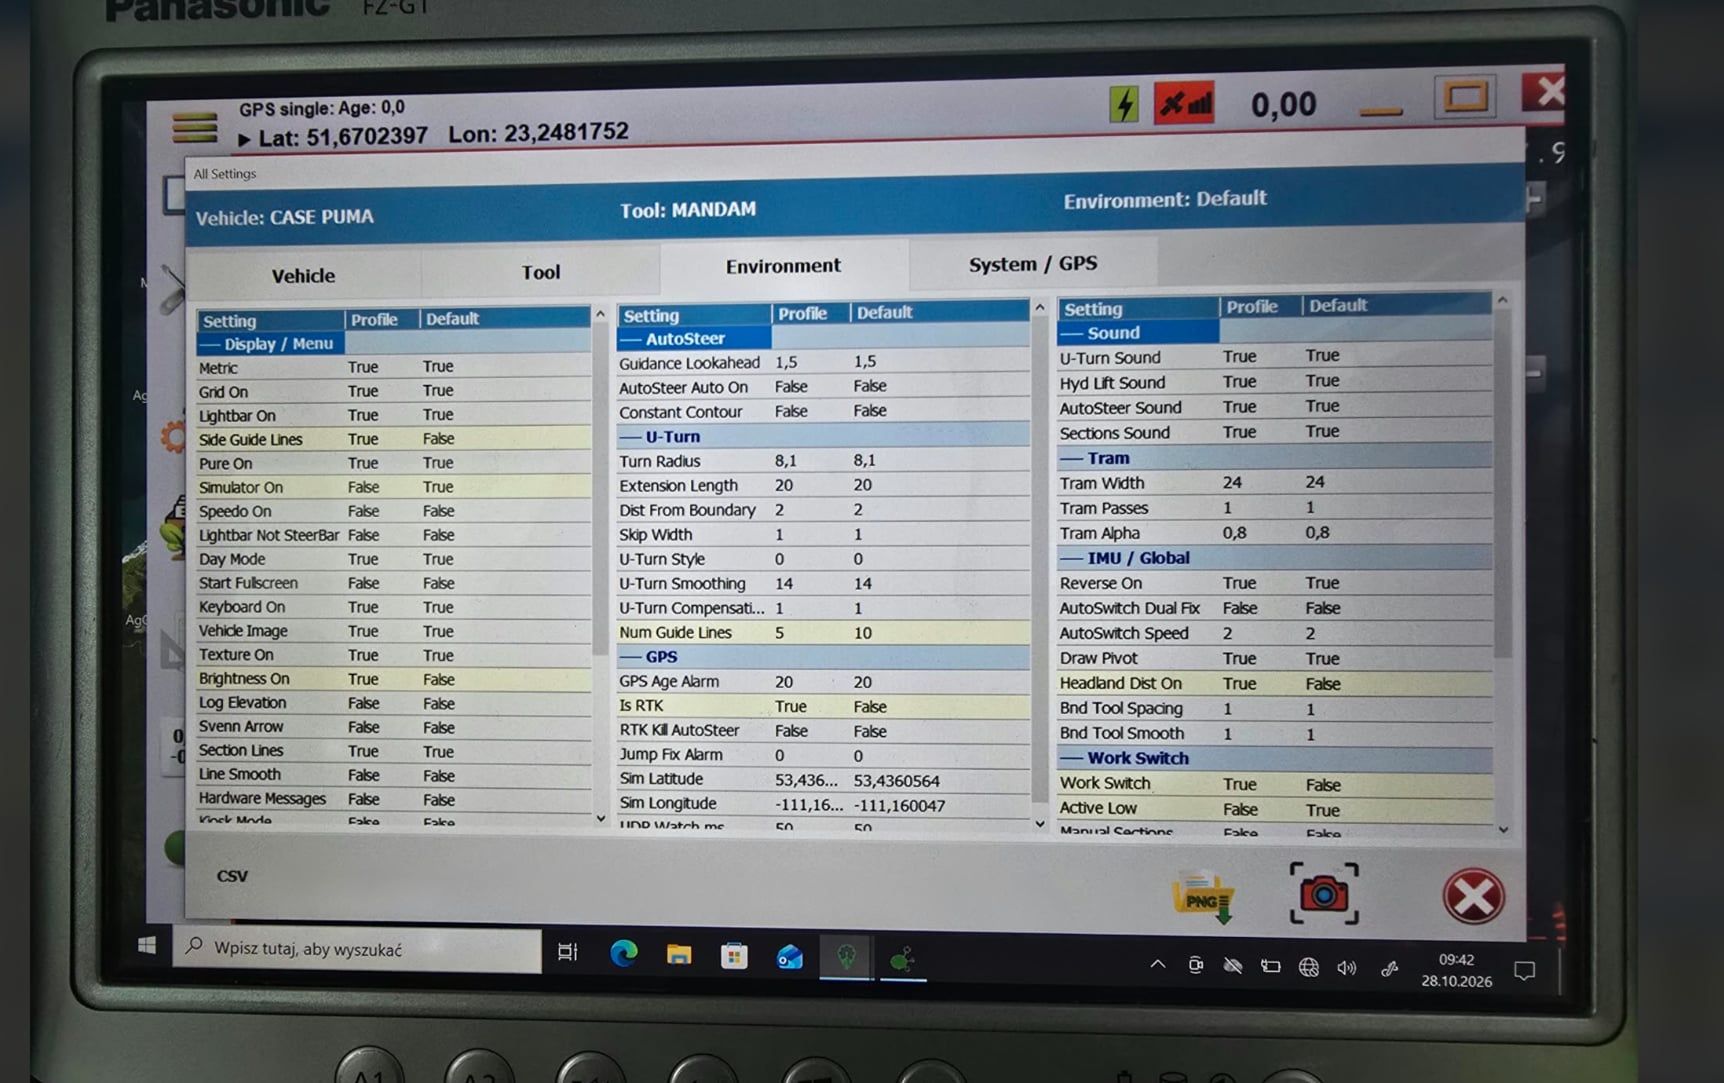
I’m currently using 95% IMU Fusion with a BNO085 on a standard AIO v4.5 board . The board is mounted on the right side of the driver’s seat, with the 23-pin AMPSEAL connector facing the front of the tractor . The X-axis orientation is configured accordingly in AgOpenGPS.

What steer settings you on?
Tilt the pcb to the right you get positive roll and negative to the left

For a keya id start with min to move 20. Pgain 40, max limit 150. Steer response 3

I’ve tried different settings and functions in AgOpenGPS, but nothing seems to solve the problem.

I’m starting to suspect that something might be wrong with the heading calculation, but I honestly have no idea what exactly is causing it.

When I use the manual Drive mode and set a fixed steering angle, the tractor follows it perfectly. However, as soon as I enable autosteer on an AB line, it starts making irregular left/right corrections.

Can you post a video of what exactly is happening?

Case Puma AoG issue

I have two tractors running AgOpenGPS. One uses a Keya steering motor, while the other uses the factory hydraulic steering system.

I’ve tried many different steering settings on both tractors, including Gain, Min, Max, Look Ahead, IMU Fusion and other parameters, but nothing seems to improve the situation.

Both tractors still have very irregular left/right deviations of up to around 8 cm from the AB line. The corrections are not smooth or sinusoidal, and I can’t get either tractor to follow a straight line consistently.

The video is an older recording, but it shows exactly the kind of problem I’m still experiencing.

Both completely different setups with the same issues sounds like a setting issues.

Is the f9p configuration correctly at 10hz

This video suggests something is either wrong with your gps or your imu.